Nereus at Wilhelmus Lab
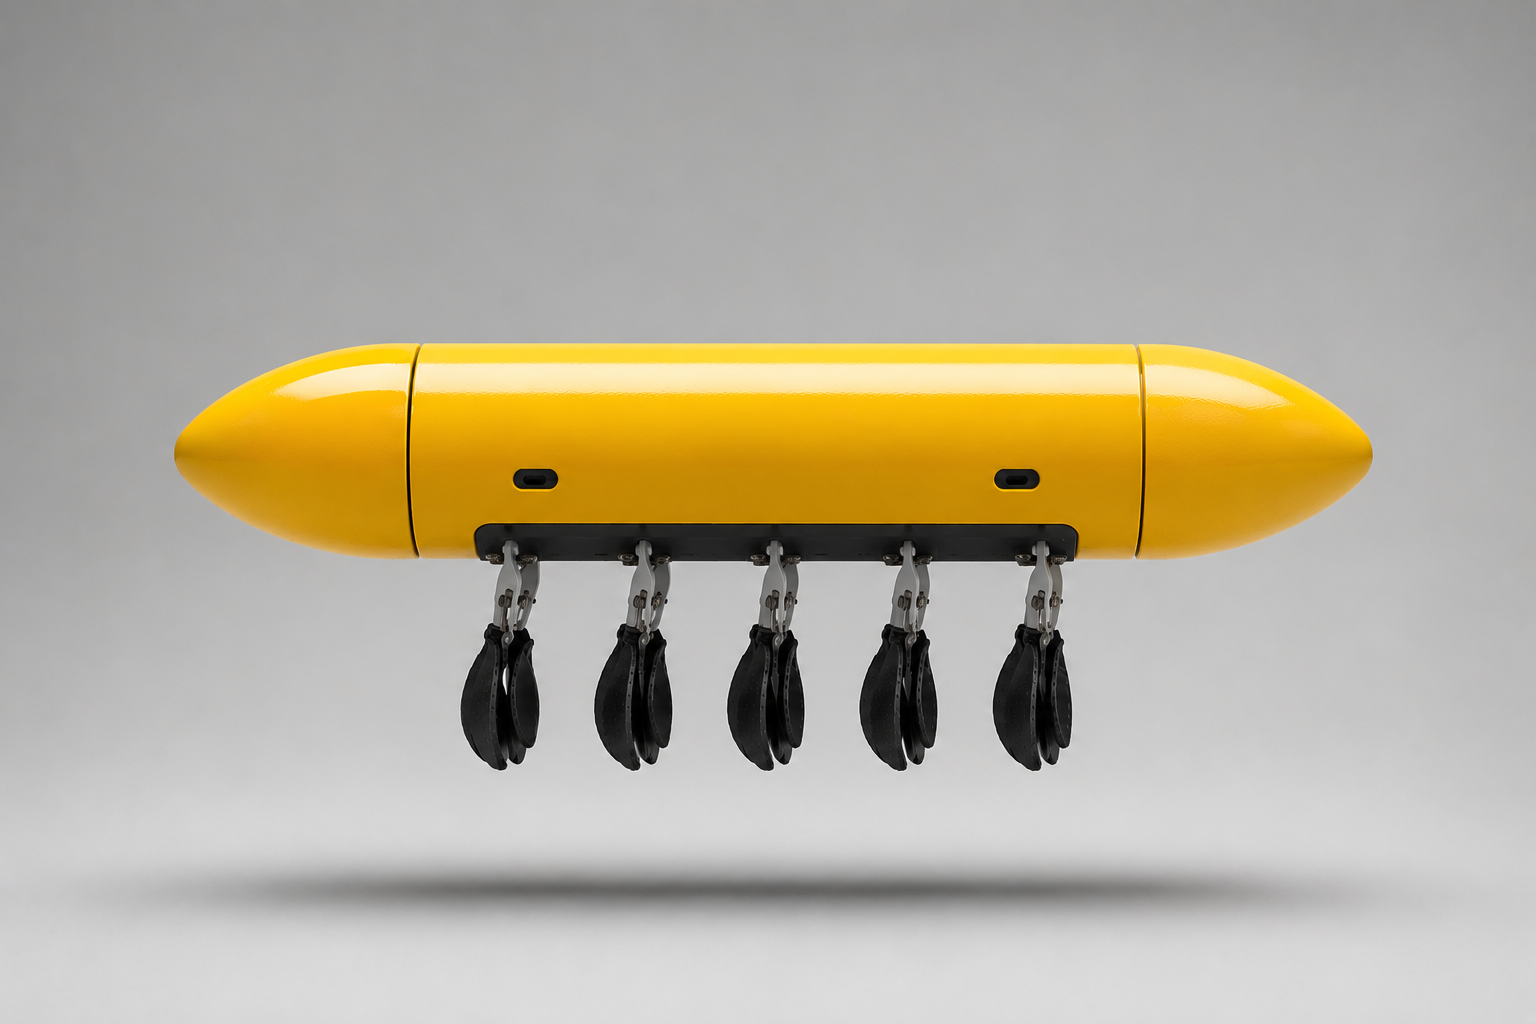
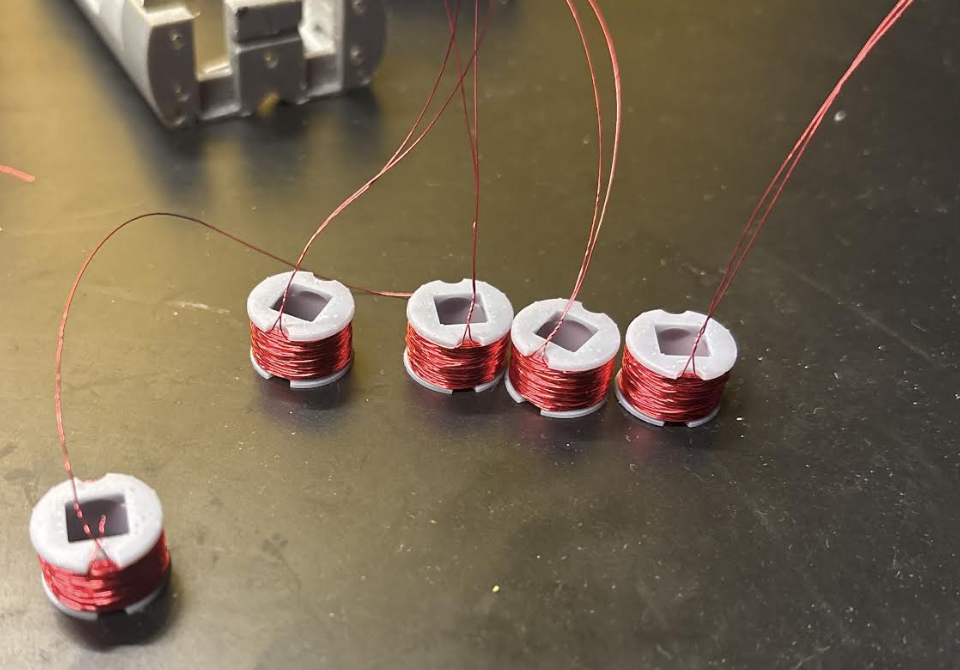
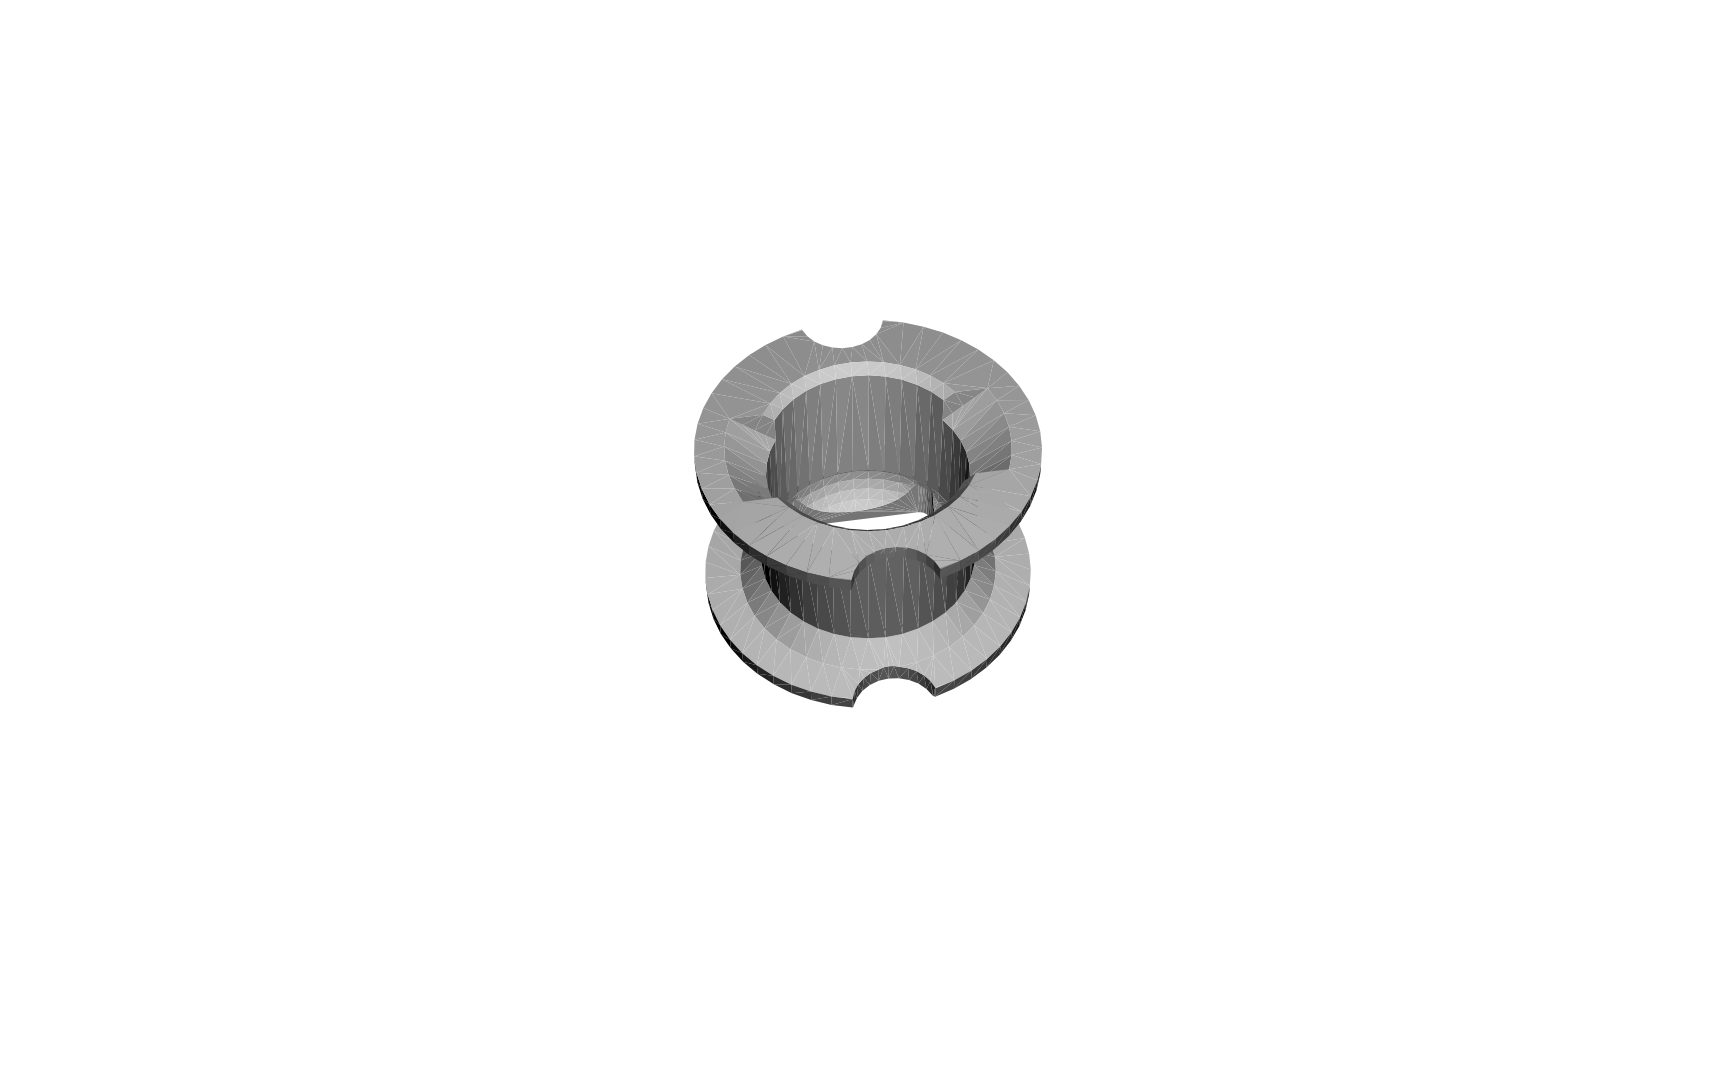
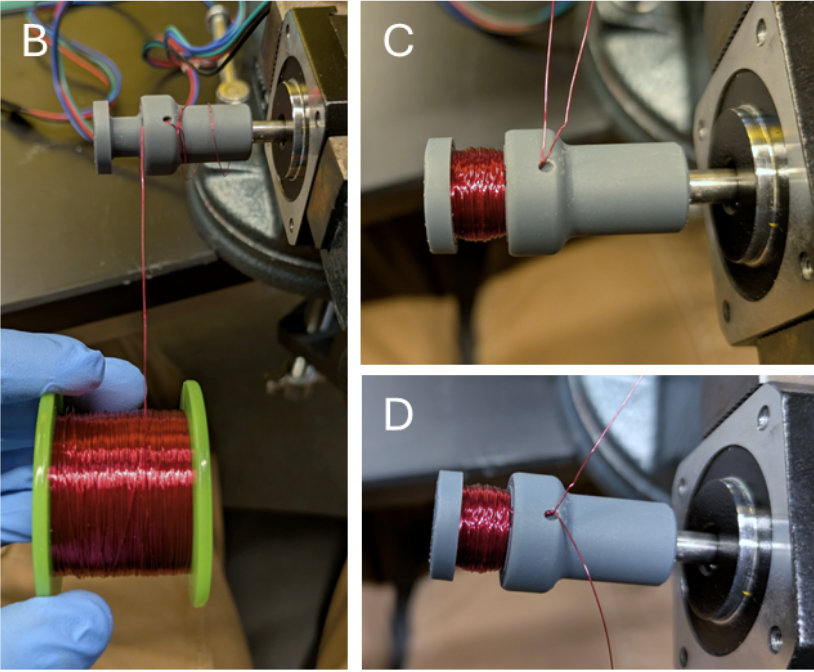
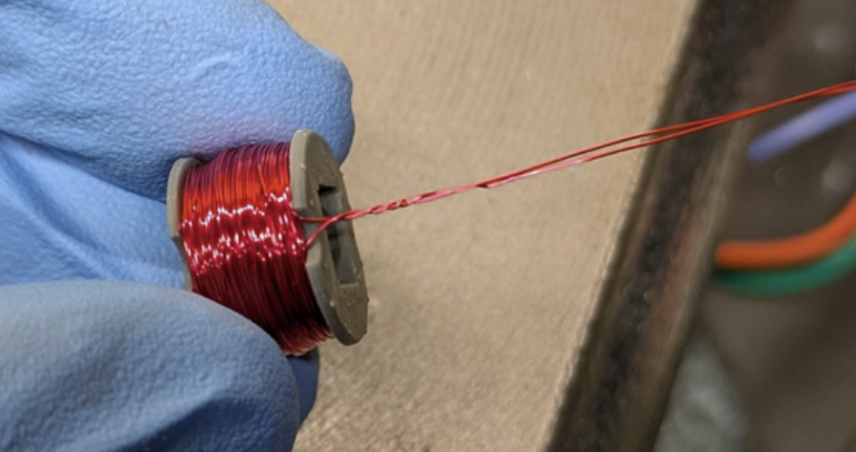
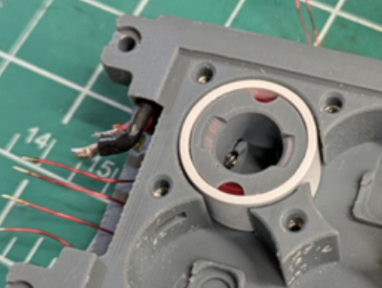
As a member of the Wilhelmus Lab at Brown, I manufactured coils for the submersible Nereus robot. Fabrication process included 3D printing & coil winding. Tools included CAD, stepper motor control, & Arduino IDE.
As a member of the Wilhelmus Lab at Brown, I manufactured coils for the submersible Nereus robot. Fabrication process included 3D printing & coil winding. Tools included CAD, stepper motor control, & Arduino IDE.